
Robots continue to multiply across factories, campuses and disaster zones. But the machines are only as smart as the maps and models feeding them. That was one of the key takeaways of the “Emerging Geospatial Capabilities in Operation” panel at Geo Gov Summit 2026, where, among others, three founders building at the intersection of geospatial AI and robotics outlined their shared thesis that GeoAI is becoming the sensory and reasoning layer that lets ground robots, humanoids and drones actually understand the world they operate in.
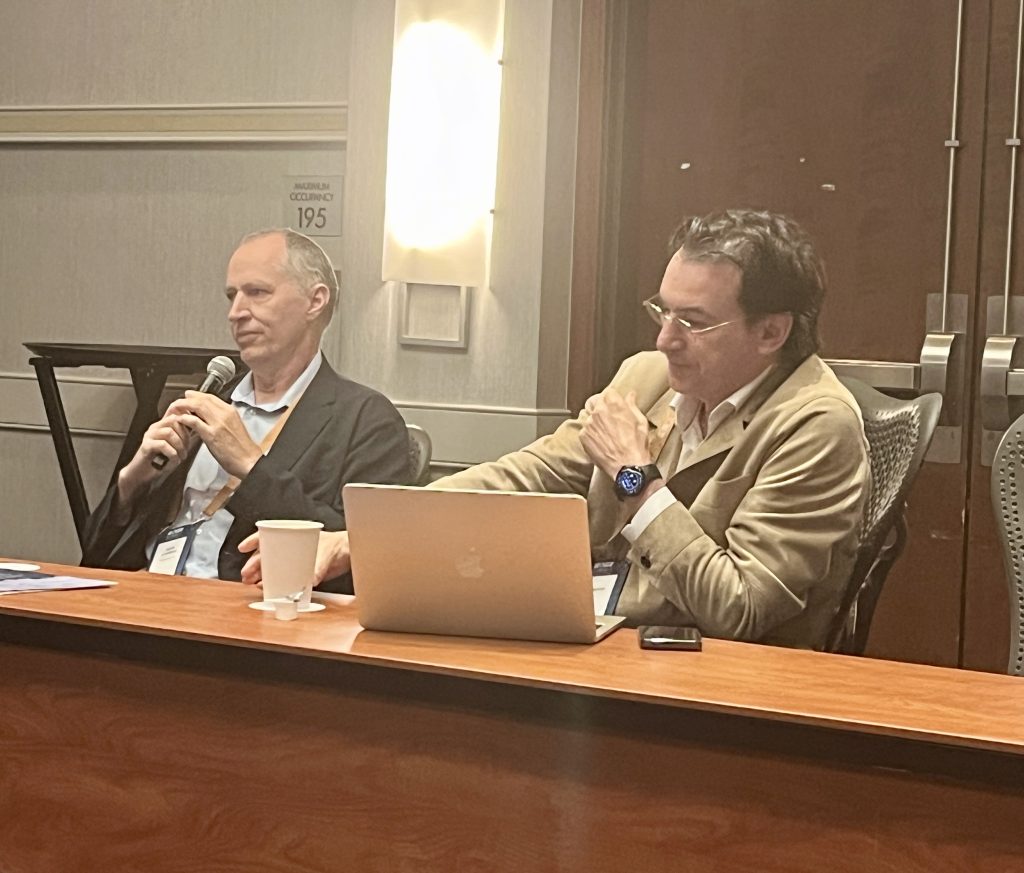
Moderated by Peter Griffin, Geospatial Project Manager at Dewberry, the panel, which also included other experts, focused on implementation examples and lessons learned as digital twins, advanced spatial processing and robotics move from research into daily operations. Three speakers carried that concept furthest:
- Rishi Madhok, CEO and co-founder of TerraByte, who is building foundation models that turn satellite pixels into searchable intelligence;
- Igor Starkov, CEO of Teleworker AI, who orchestrates fleets of robots through digital twins; and
- Luis Sentis, CEO and co-founder of AIVE AI, a humanoid robotics veteran now wiring geospatial reasoning into UAVs and factory-floor machines.
All three bring distinct global experience shaped by careers spanning India by way of Microsoft, Russia, and Spain by way of two decades in robotics research. Each brought a different vantage point on the same GeoAI – robotics convergence.
GeoAI Turns Satellite Pixels Into Instant Answers

Madhok opened his segment by tracing his path from Carnegie Mellon, through Uber’s self-driving car division, to Microsoft, where he spent six years working on endeavors that included Project Maven, the Pentagon-linked computer vision program now run by the National Geospatial-Intelligence Agency, and Microsoft’s Planetary Computer. He left last year to found TerraByte, a company he described as building toward “earth intelligence,” or the ability to run inference directly on satellite observations rather than waiting for images to be downloaded, processed and interpreted by hand.
He illustrated the problem with a simple example. A port manager wants to know which ships are waiting and where they can dock. Answering that question today means buying imagery, then paying analysts or software to interpret it, a workflow slow enough that Madhok says it has kept commercial geospatial adoption well behind the government sector. TerraByte’s answer is a geospatial foundation model trained, in his words, on more than a million different concepts rather than the five or ten object classes typical of older computer vision systems. The model fuses electro-optical, synthetic aperture radar, thermal and hyperspectral data, a combination very few systems attempt in a single model.
Madhok showed how a plain-language query such as “show me all the power plants under construction in China in the last two weeks” returns ranked results. He searched for marble quarries in Turkey and a hypothetical starship launch pad, describing scenes in natural language that would be impossible to find on Google Maps or Apple Maps because those platforms depend on user-generated metadata rather than raw pixel understanding. TerraByte’s tools returned matches in under thirty seconds. Through a new partnership with the satellite data marketplace SkyFi, users can also pull fresh imagery for as little as twenty dollars, a price point Madhok said breaks the traditional barrier that has kept geospatial intelligence locked inside government and defense budgets.
He also demo’ed a live wildfire tracking layer, built on open-source Sentinel imagery paired with NASA data, that updates hourly. Pulling it up mid-presentation, Madhok noted he could see at least five active forest fires in the northern Virginia area as he spoke. His closing vision pushed this even further. Models, he said, run onboard satellites themselves, so that instead of streaming raw pixels to the ground, a spacecraft would send back only the interpreted result. As he put it, the goal is to let the mission shape the next observation, meaning the system decides in real time what to look at next, with the final call still resting with a human on the ground.
Later in the discussion, Madhok returned to a lesson from his self-driving years that applies directly to robotics adoption. “The technology was barely the problem,” he said. “It was about how we establish trust.” He pointed out that he lives in San Francisco, where every third car is autonomous, while the same vehicles are absent from most of the country, and argued that a robot has to demonstrate it is roughly ten times better than a human before people will delegate to it. He framed the delay as healthy rather than as an obstacle.
Digital Twins Give Building Robots a Brain
Starkov’s path to robotics ran through building information modeling and digital twins, a business he sold to Siemens five years ago. After several years inside Siemens, he set out to populate those digital twins with something new: fleets of physical robots that actually do work inside the buildings the twins represent. His company builds what he calls an orchestration layer, essentially an operating system, that lets facility operators see what every robot on a property is doing, issue it commands and confirm the robot understood the task.
Starkov was clear about why that layer matters, pointing to a recent controversy involving humanoid robotics company Agility Robotics, which recently went public through a SPAC deal valuing it at roughly two and a half billion dollars despite reporting under two million dollars in annual revenue. Hardware alone does not sell. “It turns out that they almost didn’t sell robots. They have a billion dollar valuation while nobody knows what to use those robots for,” he told the room. The industry’s real bottleneck, he said, is not building better machines but making the machines useful within existing workflows.
He provided the Javits Center in New York, a five-city-block, three-million-square-foot convention venue, as a flagship example of how this could work. Teleworker AI built a full digital twin layering legacy building systems such as BIM, CMMS and GIS underneath a fleet of cleaning robots, delivery machines, and inspection robots there. The system has to reconcile indoor building models with outdoor GIS data, since a campus the size of an airport or university does not stop at the building’s walls. On the ground, Starkov showed robots that negotiate shared space autonomously, essentially telling each other “I’m working here, let me go in” so multiple machines can operate without colliding.
One of the coolest use cases he demonstrated was a robot dog, costing only a few thousand dollars, that walks a construction site every night on its own, capturing progress photos and reporting them back to the project owner by morning. During the day, the same low-cost robot switches roles to serve as roving physical security. Starkov also described an augmented reality interface that lets a technician see through walls. A robot can flag a problem such as a shutoff valve located behind drywall. An AR headset overlays its exact location so a human colleague standing nearby can see it without demolition. He compared the integration challenges to the building automation world, where incompatible proprietary systems from vendors like Honeywell and Siemens eventually converged around common software layers such as Niagara. He predicted robotics is heading toward the same consolidation, just earlier in the process. As he put it, describing the current maturity of robot manufacturer APIs, most vendors are still just focused on making sure their machines walk without falling over.
Humanoid Robots Need Maps That Reach, Not Just Walk

Sentis brought perhaps the deepest robotics pedigree on the panel, having built humanoid robots for twenty-eight years and founded the company, Apptronik, with a scale of interest in humanoids he admitted he never expected. His path to the geospatial community started, by his own account, through childhood immersion in manga and later through US Navy and NASA funded humanoid robotics programs, which led his team into wildfire detection competitions, aircraft construction and eventually AI software for drones that matches satellite data with a drone’s own onboard camera view for localization.
His central argument was that factories are geospatially blind. He pointed out that the world holds roughly twenty million manufacturing lines, yet very few of them have current digital maps of what is actually happening on the floor, even as automated mobile robots, humanoids and wheeled robots move through those same spaces constantly. “There’s very little online updates of the map,” he said. The industrial robotics world should borrow directly from GIS practice to build living digital twins of factory floors rather than relying on outdated static blueprints.
Sentis’s most striking comments revolved around what mapping even means once humanoid hands enter the picture. Robotic navigation has historically solved for six degrees of freedom, essentially treating a robot as a single rigid body moving through space. Manipulation breaks that model completely, since a humanoid must reason about the position of every individual finger relative to a surface it wants to grasp, turn or repair. “We need to create maps not only for walking, but also for reaching,” he said, a comment that captured this idea that geospatial data models built for vehicles and drones will need an entirely new layer of precision to serve dexterous manipulation tasks like factory repair.
He also used his stage time for an unscripted demo of generative design tools, describing how he prompted an AI system called GPT Astra to design a submarine, printable at home, so he could test free-floating dexterity and thruster control in a swimming pool before attempting flight. He raised an open ethical question about that same accessibility: if a middle schooler with no formal training can now design working robotic hardware and geospatial matching algorithms through AI assistance, does that democratize the field or erode the expertise barrier that has defined it? He offered no answer, saying only that he remains unresolved on where that access should land.
Why the Three Threads Converge
Strip away the different focus areas and entry points for these speakers, and a single pattern connects them. Madhok’s foundation models make raw satellite imagery queryable in plain language, turning months of analyst work into a search bar. Starkov’s orchestration software takes that same spatial awareness indoors, giving human operators visibility and control over fleets of low-cost robots doing repetitive physical work. Sentis pushes the frontier further still, arguing that even factory floors and a robot’s own fingertips need updated, living geospatial models to support the next generation of humanoid manipulation.
The panel made clear that robots are not becoming more capable primarily because of better motors or batteries. They are becoming more capable because GeoAI is finally giving them reliable, real-time, and increasingly cheaper ways to know exactly where they are, what surrounds them and what to do next.
GeoAI isn’t just mapping the world anymore. It’s teaching robots how to move through it.